製品

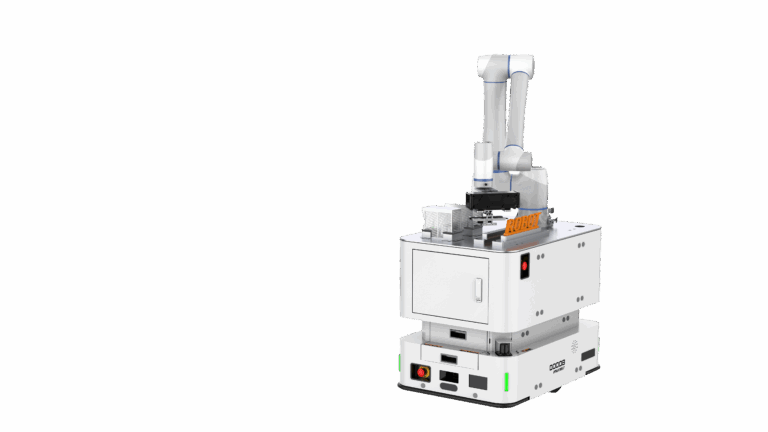
QC3-10LDE1 Mobile Collaborative Robot

A mobile collaborative robot is an intelligent automation solution designed for autonomous material transport, precise picking, and flexible workstation support. Equipped with a mobile base and integrated collaborative robotic arm, it can navigate between work areas and perform handling, loading, unloading, and assembly-related tasks. Ideal for manufacturing and warehouse environments, it improves productivity, enhances process flexibility, and reduces repetitive labor costs.

600

定格荷重(kg)

1092

回転径(mm)

1200

Rated running speed(mm/s)

930*640

Rated loading size L*W(mm)
製品  詳細

主な機能

Integrated Mobile Manipulation

  • Mobile Base and Cobot Arm: Combines autonomous navigation with a collaborative robotic arm for material handling and workstation operations.
  • Flexible End Effector Integration: Supports customized grippers, cameras, and tooling for picking, loading, unloading, inspection, and assembly tasks.

スケーラブルなデザイン

  • モジュール式拡張: Enables rapid deployment with configurable arm, vision, and end-effector options.
  • System Integration: Connects with production equipment, conveyors, MES/WMS systems, and other external hardware.

適応型パフォーマンス

  • 自律航行: Moves independently between workstations using navigation methods suited to the operating environment.
  • Precision Manipulation: Combines accurate positioning with flexible arm movement for repeatable pick-and-place operations.
  • Collaborative Operation: Designed to work safely alongside operators and production equipment in shared work areas.
  • Intelligent Task Execution: Supports task scheduling, automatic docking, material recognition, and process-based operation.

シーンに合わせて使える汎用性

  • Multi-Process Support: Suitable for material transfer, machine tending, bin handling, inspection, sorting, and light assembly.
  • Flexible Deployment: Adapts to changing production layouts without fixed conveyors or extensive infrastructure changes.
  • Continuous Operation: Supports automatic charging and scheduled task execution to reduce manual handling.
  • Fleet Collaboration: Multiple robots can coordinate material movement and workstation service for higher throughput.

応用事例

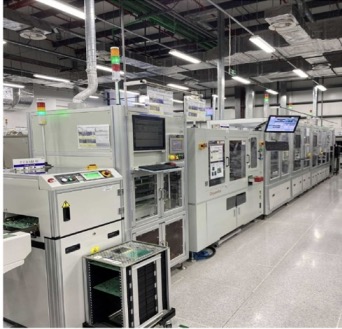
Machine tending and CNC support

Inspection, sorting, and light assembly

 
基本パラメータ ナビゲーションモード 20個のバーコード/L-SLAM/V-SLAM
寸法(長さ×幅×高さ)(mm) 950*650*1620
回転径(mm) 1092
昇降プラットフォームの寸法(mm) /
持ち上げストローク(mm) /
昇降構造タイプ /
体重(kg) 286
Loading weight(kg) 600
人間と機械の相互作用 デジタルチューブ
安全性 前面保護 レーザ
後部保護 –
側面保護 –
音と光による警報 サポート
レーザークリアランスランプ –
バンパーストリップ サポート
緊急停止ボタン サポート
モーションパフォーマンス 定格走行速度(空車時)(mm/秒) 1200
定格加速度(空車時)(mm/s²) 1000
位置決め精度(mm)/(°) ± 10 / ± 1
バッテリー性能 実行時間(時間) 8
充電時間(時間) ≤ 2


証明書

関連している  製品
WeChat02d44b0e2d7770bbd95d7f4c8dd3372e
自動車部品の自動生産ライン
WeChatf6cb49d4ca9b4c2512fc56d086582870
自動FCT試験装置
WeChat8695b2732ad5a49b799cd5bab7d170c3
自動EOLテスト装置
WeChat0dc43e142e0d8e330cb8c4ba38538f1b
自動AOIテスト装置
jaJapanese